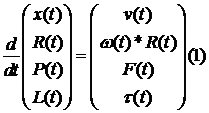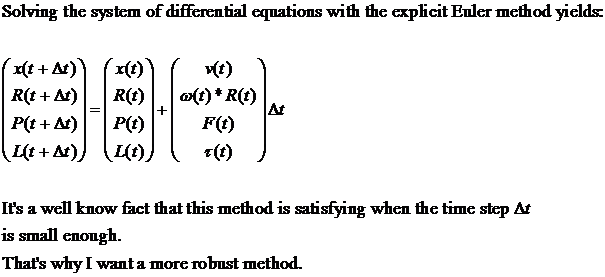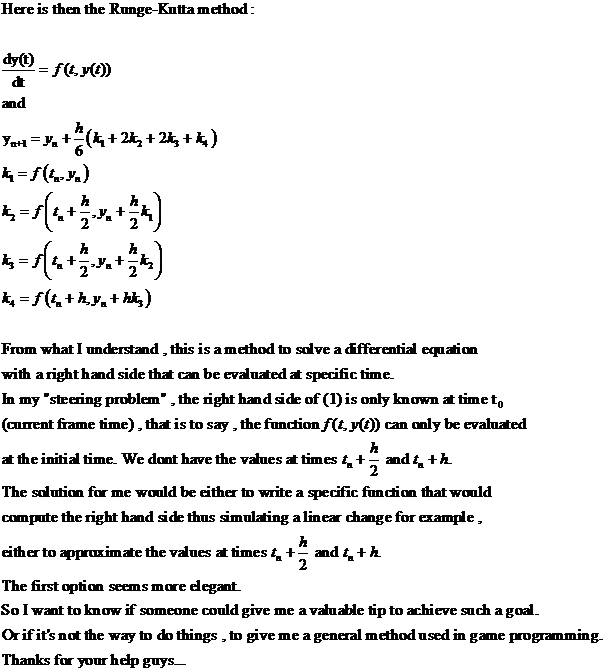Original Post

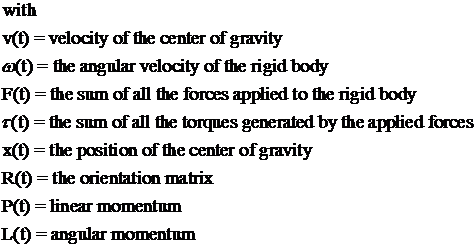
Hi everybody... I was trying to simulate steering and I've noticed some unwanted effects. They obviously must stem from the fact I'm updating my state variables with the explicit Euler method. I want to use another scheme(RK4): the forces and torques I compute should therefore vary between each update.I could simulate a linear,quadratic,exponential,etc variation of my forces and torques...The problem is the variable to update are vectors and matrices.While it is easy to imaginate a linear variation of vectors , it's a bit hard to imagine the same thing for matrices. Well,my "physics engine" is based on Baraff's paper(a great one) and I define the same state variables.For people who want a link: [link]http://www.cs.cmu.edu/~baraff/sigcourse/notesd1.pdf[/link] Could you tell me what function F(t)(see definition on Baraff's paper,page 16) I could use for a steering problem? Edit:it seems that forces and torques variations are only required...the others variables being "derived" from them.However,I prefer not removing the question to see if someone could come up with an interesting idea. [Edited by - johnstanp on May 6, 2008 12:19:52 PM]